
Autonomous robots from firmware to fleet: ROS 2 stacks for quadruped patrol and rail inspection, drivers, embedded controllers and on-robot AI perception, built and run in Indonesia.


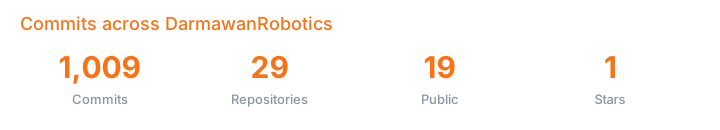


Rendered every 12 hours by lowlighter/metrics from this organization's repositories.
| Project | What it is | Stack |
|---|---|---|
| Pashupati | Autonomous patrol and inspection stack for quadruped robots: LiDAR teach and repeat, obstacle avoidance, on-robot AI inspection and people counting, driven from a handheld controller and commanded from NETRA | ROS 2 Humble, Python, C++ |
- Darmawan Web: the command centers, ground control stations and dashboards for these robots.
- @agus-darmawan: I Wayan Agus Darmawan, who builds and maintains both.
